KI-Beratung Beta

  • Produktbild: Modeling and Nonlinear Robust Control of Delta-Like Parallel Kinematic Manipulators
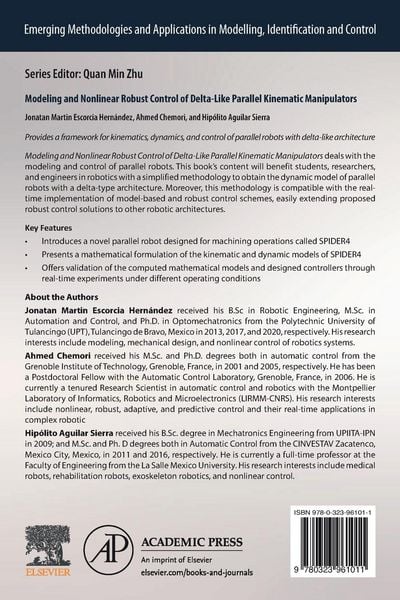
  • Produktbild: Modeling and Nonlinear Robust Control of Delta-Like Parallel Kinematic Manipulators

Modeling and Nonlinear Robust Control of Delta-Like Parallel Kinematic Manipulators

134,99 €

inkl. gesetzl. MwSt., Versandkostenfrei


Beschreibung

Produktdetails

Einband

Taschenbuch

Erscheinungsdatum

17.01.2023

Verlag

Elsevier Science & Technology

Seitenzahl

172

Maße (L/B/H)

22,6/14,8/1,1 cm

Gewicht

296 g

Sprache

Englisch

ISBN

978-0-323-96101-1

Beschreibung

Produktdetails

Einband

Taschenbuch

Erscheinungsdatum

17.01.2023

Verlag

Elsevier Science & Technology

Seitenzahl

172

Maße (L/B/H)

22,6/14,8/1,1 cm

Gewicht

296 g

Sprache

Englisch

ISBN

978-0-323-96101-1

EU-Ansprechpartner

Elsevier B.V.
Radarweg 29
1043 NX Amsterdam
NL
productsafety@elsevier.com

Herstelleradresse

Elsevier Science & Technology
London Wall 125
EC2Y 5AS London
GB
tradeorders@elsevier.com

Noch keine Bewertungen vorhanden

Verfassen Sie die erste Bewertung zu diesem Artikel

Helfen Sie anderen Kundinnen und Kunden durch Ihre Meinung.

Kundinnen und Kunden meinen

Bewertungen (0)

  • Produktbild: Modeling and Nonlinear Robust Control of Delta-Like Parallel Kinematic Manipulators
  • Produktbild: Modeling and Nonlinear Robust Control of Delta-Like Parallel Kinematic Manipulators
  • 1. Introduction
    2. Literature review about modelling and control of PKMs
    3. Description and Modelling of Experimental platforms
    4. Proposed Robust Control Solutions
    5. Numerical simulations and Real-time experiments
    General Conclusion
    Appendices
    A Proof of lemma 1
    B Trajectory points for SPIDER4
    B1 Trajectory points for Scenario 1
    B2 Trajectory points for scenario 2