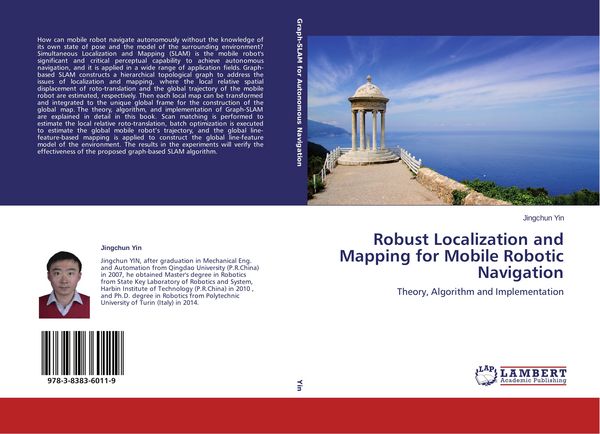
Robust Localization and Mapping for Mobile Robotic Navigation Theory, Algorithm and Implementation
-
- Englisch ausgewählt
54,99 €
UVP
61,90 €
inkl. gesetzl. MwSt.,
Beschreibung
Produktdetails
Einband
Taschenbuch
Erscheinungsdatum
30.04.2014
Verlag
LAP LAMBERT Academic PublishingSeitenzahl
132
Maße (L/B/H)
22/15/0,9 cm
Gewicht
215 g
Auflage
1. Auflage
Sprache
Englisch
ISBN
978-3-8383-6011-9
How can mobile robot navigate autonomously without the knowledge of its own state of pose and the model of the surrounding environment? Simultaneous Localization and Mapping (SLAM) is the mobile robot's significant and critical perceptual capability to achieve autonomous navigation, and it is applied in a wide range of application fields. Graph-based SLAM constructs a hierarchical topological graph to address the issues of localization and mapping, where the local relative spatial displacement of roto-translation and the global trajectory of the mobile robot are estimated, respectively. Then each local map can be transformed and integrated to the unique global frame for the construction of the global map. The theory, algorithm, and implementation of Graph-SLAM are explained in detail in this book. Scan matching is performed to estimate the local relative roto-translation, batch optimization is executed to estimate the global mobile robot's trajectory, and the global line-feature-based mapping is applied to construct the global line-feature model of the environment. The results in the experiments will verify the effectiveness of the proposed graph-based SLAM algorithm.
Noch keine Bewertungen vorhanden
Verfassen Sie die erste Bewertung zu diesem Artikel
Helfen Sie anderen Kundinnen und Kunden durch Ihre Meinung.
Kurze Frage zu unserer Seite
Vielen Dank für dein Feedback
Wir nutzen dein Feedback, um unsere Produktseiten zu verbessern. Bitte habe Verständnis, dass wir dir keine Rückmeldung geben können. Falls du Kontakt mit uns aufnehmen möchtest, kannst du dich aber gerne an unseren Kund*innenservice wenden.
zum Kundenservice